> For the complete documentation index, see [llms.txt](https://delta-robotics.gitbook.io/docs/llms.txt). Markdown versions of documentation pages are available by appending `.md` to page URLs; this page is available as [Markdown](https://delta-robotics.gitbook.io/docs/hardware/thermoflex/tf-mk1-muscle.md).
# TF Mk.1 Muscle
The TF Mk.1 Muscle, a dual-coil Nitinol actuator that lifts up to 25 pounds in about 2 seconds on a 25 V supply, with full electrical and mechanical specs
*Pronunciation: Ther-moh-fleks mark one muscle*
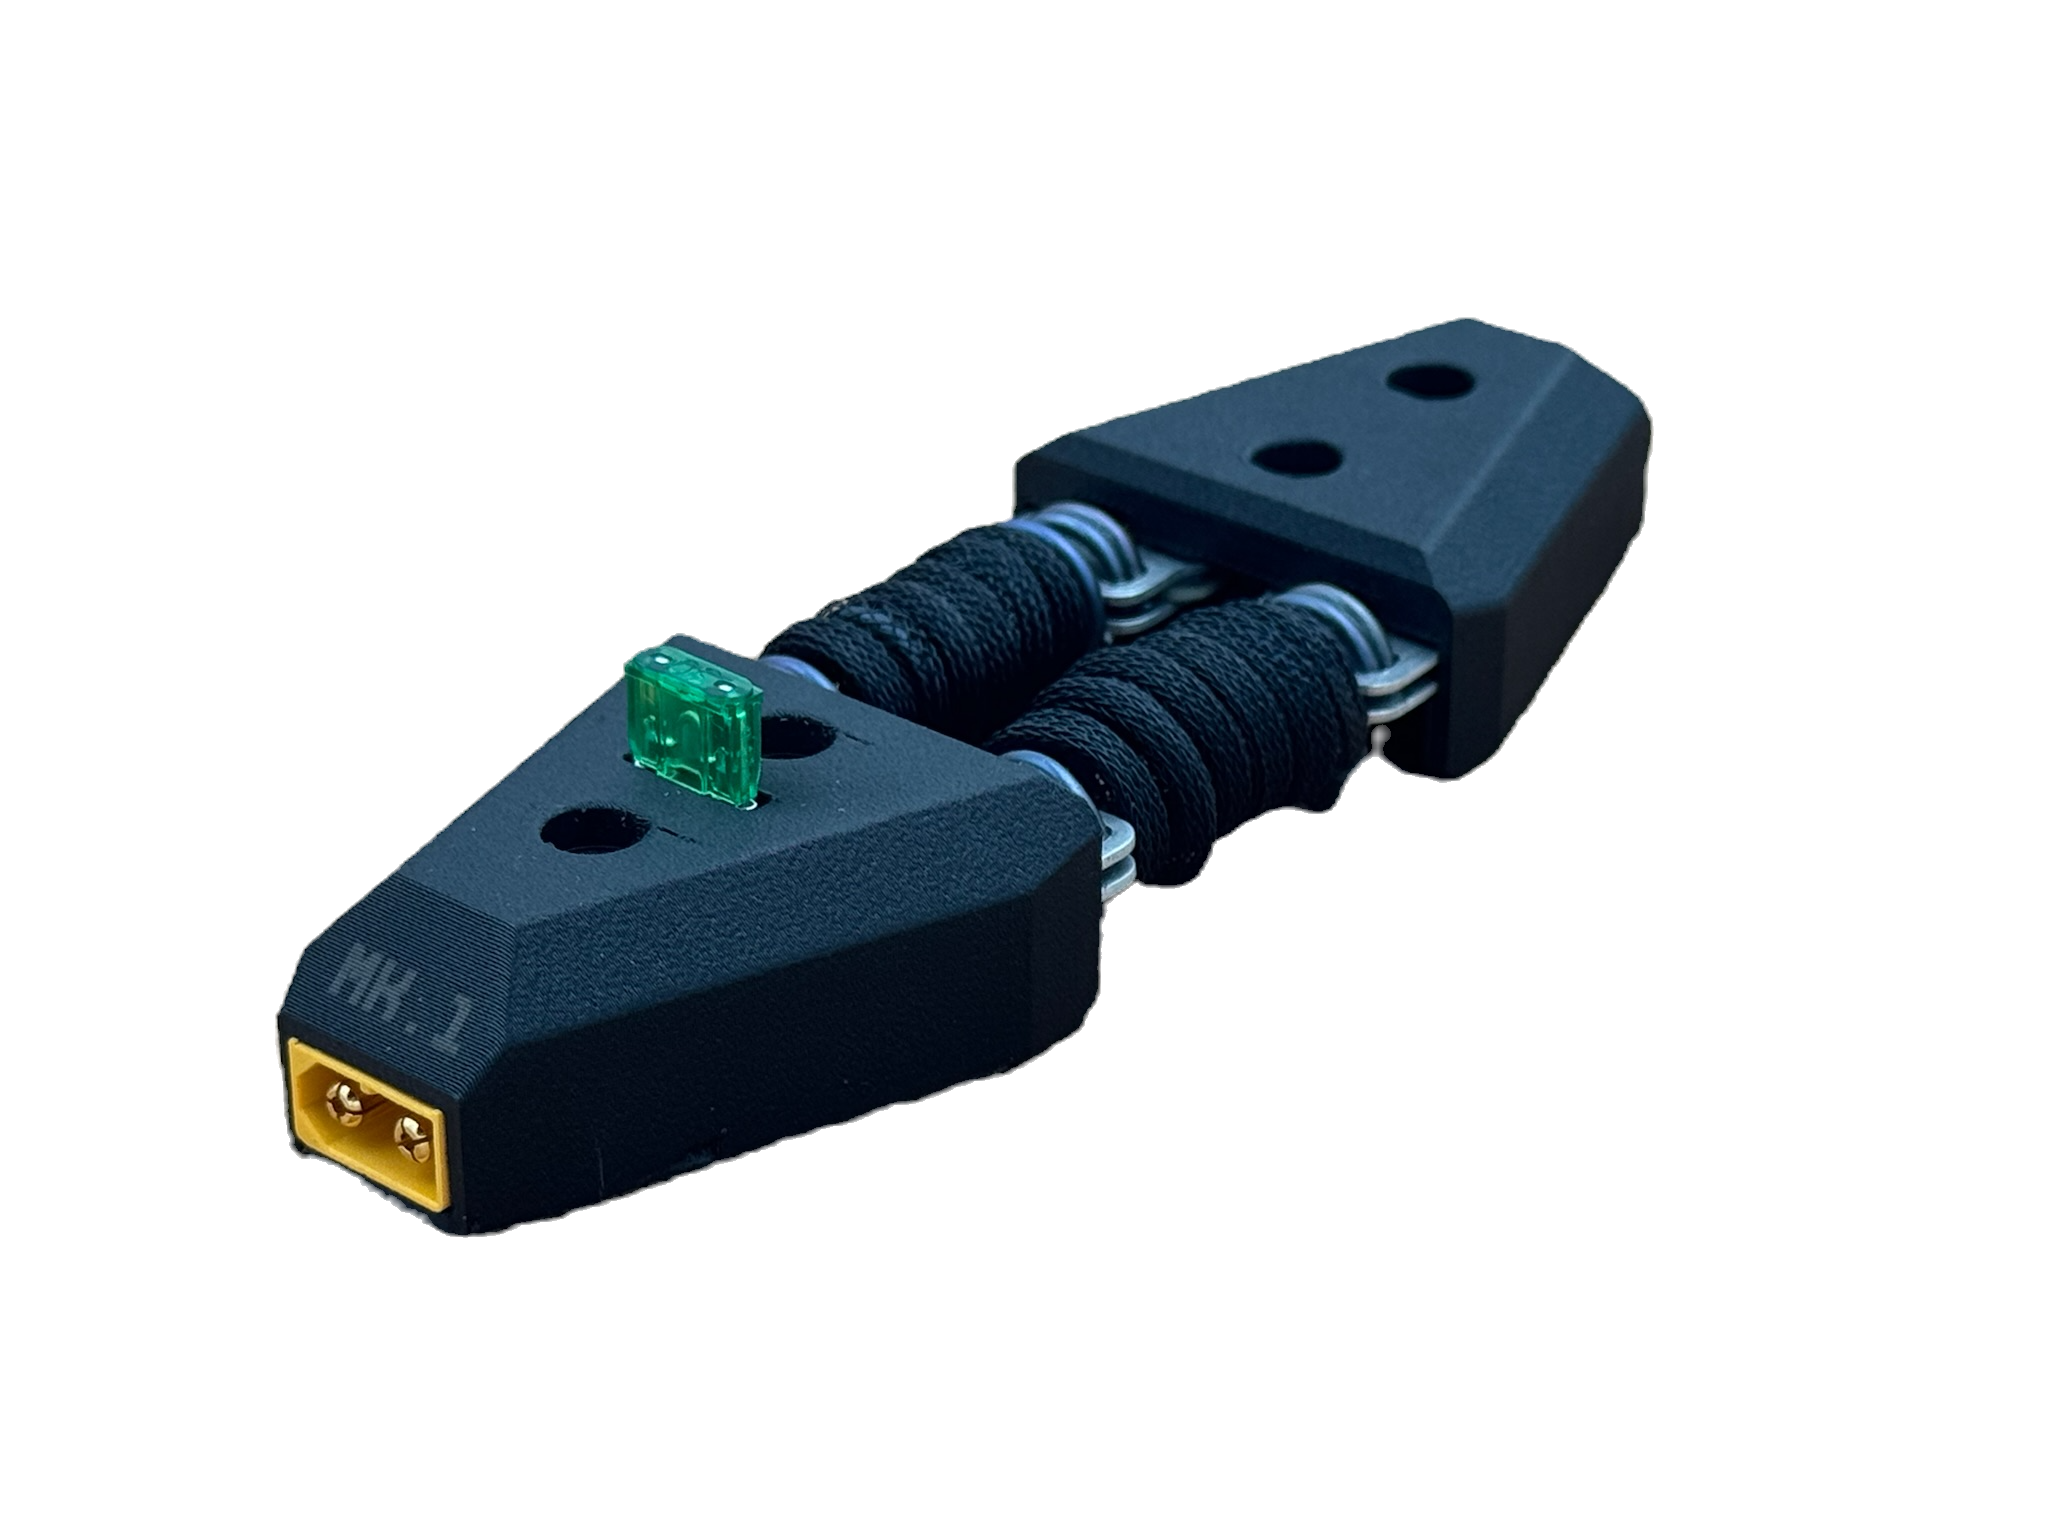
The TF Mk.1 Muscle is a dual-coil Nitinol actuator. It contracts when heated by current and returns as it cools, delivering muscle-like linear pull for robotics and motion projects. Drive it with the TF Node Controller and the ThermoFlex Python API.
The TF Mk.1 Muscle.
## Specifications
### Electrical
| Parameter | Minimum | Maximum |
| --------------------- | -------------------- | ---------------------- |
| Nominal voltage | 3 V | 25 V |
| Resistance | 235 mOhms (Af) | 250 mOhms (Mf) |
| Instantaneous current | (Dependent on PWM %) | 106 A (2s contraction) |
### Mechanical
| Parameter | Minimum | Maximum |
| ---------- | ------------------------------ | ------- |
| Pull force | 5 lbs (extension return force) | 25 lbs |
### Timing
| Parameter | Minimum | Maximum |
| ---------------- | ------- | --------- |
| Contraction time | - | 2s @ 25 V |
Question about specific values? Ask Kevin:
## Contraction test results
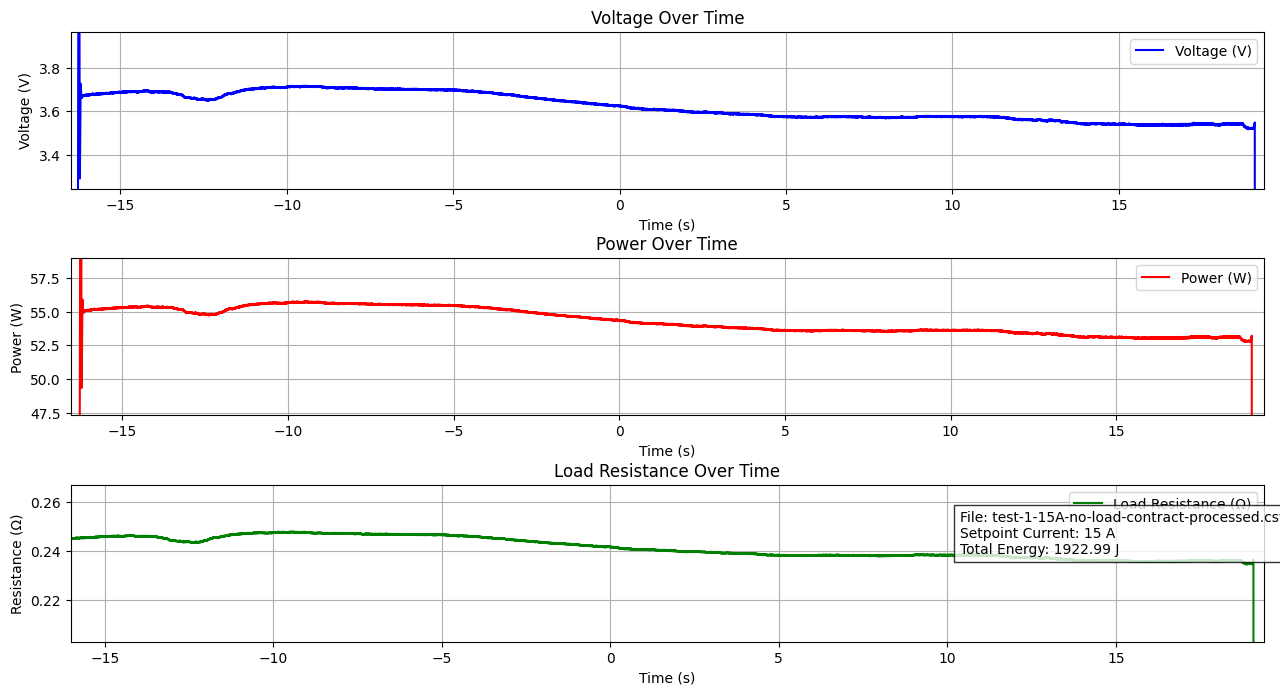
A single full actuation, measured on the bench with a current-limited supply.
| Test parameter | Value |
| ----------------------- | --------------------------------------------------------- |
| Power supply | Variable supply set to 15 A, monitored on an oscilloscope |
| Load | None |
| Set current | 15 A |
| Time to contract (TTC) | 35.311 s |
| Total power consumption | 1923 J (about 0.5 Wh) |
What this means: the graph shows the total power consumption for a full actuation over 35 seconds. Standard actuations with the TF Node Controller are under 2 seconds.
## Related pages
* [TF Node Controller](/docs/hardware/thermoflex/tf-node-controller.md): The electronics that drive this muscle.
* [ThermoFlex Python API](/docs/software/thermoflex-python-api.md): Command contractions from Python.
* [Wire](/docs/hardware/nitinol/wire.md): The Nitinol behind the muscle.
* [Quickstart: your first flex](/docs/get-started/quickstart.md): Run your first contraction.